SpaceBrief
A Caltech robot assembled a structure in orbit, a first, according to Darpa
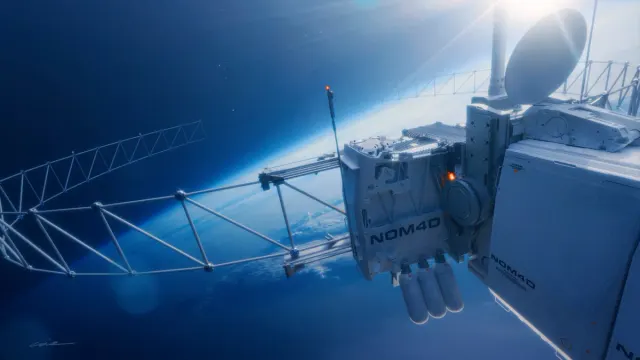
A robot designed at Caltech, a California research institute, has assembled a truss structure in space, says Darpa, the research agency of the US Department of Defense. The programme ultimately aims at constructions of several hundred metres.
According to heise online, which draws on a Darpa statement, Caltech has demonstrated for the first time the assembly of a structure in space.
The robot is a simple gantry that moves along three axes, Darpa reports. It assembled the parts with connectors designed for the occasion, along with a thin net. The agency concludes that an antenna can be assembled in space.
The structures it has in view, such as modular data centres in orbit, are too large to be launched in one piece. Assembly by hand by astronauts, as on the International Space Station, would be too onerous: robots must take it on.
Andrew Detor, who heads the NOM4D programme, speaks of structures of several hundred metres, even kilometres. At that scale, he says, nothing is feasible today.
The system was first planned as a simple ground demonstrator. Convinced by its results, Andrew Detor decided to test it in space. He says 15 months passed between the idea of an in-orbit demonstration and the launch of a working prototype on a SpaceX rocket.
Source
- heise online (Roboter) · heise.de
Also worth reading
What next