OddBrief
More than 300 parts and six motors for one task: bouncing a ball on a bat
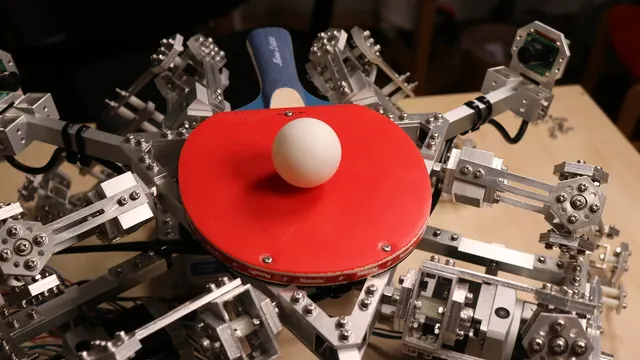
Hackaday features T-Kuhn's hexa-bouncer, a robotic platform made largely of aluminium and built for a single task: bouncing a ball.
For Hackaday, this is a very impressive robot devoted to a most mundane task. The site probably sees it as the most needlessly sophisticated machine it has come across this week.
Six stepper motors, each fitted with a planetary gearbox, each drive one arm. Clever linkages let the machine move a table tennis bat in every direction, in both rotation and translation.
A Teensy 4.0 board coordinates the motors, but the commands come from a PC. Software built with Unity and published on GitHub calculates the arm movements from two cameras that track the ball in 3D.
The machine is largely made of aluminium milled on T-Kuhn's CNC milling machine. Each arm needs 27 aluminium parts, not counting those in the base. In total, the assembly exceeds 300 parts.
According to Hackaday, T-Kuhn had developed this machine vision method of tracking the ball on another of his robots, called octo-bounce.
Source
- Hackaday (Robots) · hackaday.com