ResearchBrief
Berkeley AI agents write robot programs and test them in simulation first
UC Berkeley researchers are putting teams of AI agents in charge of writing robot programs, which they first try out in simulation. According to Interesting Engineering, a warehouse robotics company has already rolled out the improvements to 30% of its US fleet.
According to Interesting Engineering, UC Berkeley researchers have developed a method that is meant to speed up significantly the programming and training of robots for real-world tasks.
The framework, called Graph-as-Policy, breaks a complex task into simpler, reusable skills, which AI agents then assemble into a complete program.
In one demonstration, a robot had to wipe ink off a metal bar with a sponge. In under an hour, the AI system produced a physical simulation of the scene, including the deformation of the sponge.
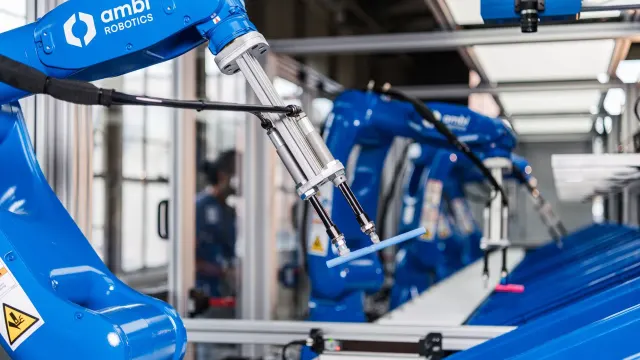
In logistics, a warehouse robotics company applied these methods to parcel sorting. According to the article, the trials increased sorting capacity by more than 15,000 parcels a year per robot, and the company extended the improvements to 30% of its US fleet.
The researchers are also releasing the code as open source, built on NVIDIA's Isaac simulation tool, along with a benchmark designed to compare robot performance on industrial tasks.
Source
- Interesting Engineering · interestingengineering.com
Also worth reading
What next