Listed

, home
FREN

Robots / Robot arm / YuMi IRB 14000

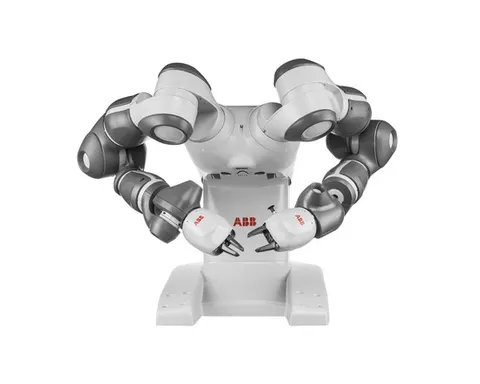
YuMi IRB 14000, official image from ABB Robotics
© ABB Robotics · official image · original page

Robot arm · Industrial

YuMi IRB 14000

Status: Announced only · Proof: statements only. Vuntum has not yet recorded any proof of a demonstration or a sale. See the rule

Use cases: Industry and production

Setting: Factory · Maker based in Switzerland

by ABB Robotics

Key facts

The YuMi IRB 14000 is a An industrial robot designed to share a workspace with people, without the protective enclosure that usually surrounds industrial robots.Read the glossary entry from ABB Robotics, a robotic arm designed for industrial robotics. Its The maximum mass a robot arm can carry at its wrist.Read the glossary entry is 500 g per arm. Its reach is 55.9 cm per arm.

Payload
500 g
Claimed by the manufacturerClaimed by the manufacturer. ABB Robotics (official product pages), accessed 5 October 2026. per arm. Original text: “Payload capacity of 0.5 kg per arm, suitable for delicate tasks”

Per arm.

Reach
55.9 cm
Claimed by the manufacturerClaimed by the manufacturer. ABB Robotics (official product pages), accessed 5 October 2026. per arm. Original text: “Reach of 0.559 m per arm, optimized for small parts assembly”

Per arm.

Repeatability
± 0.02 mm
Claimed by the manufacturerClaimed by the manufacturer. ABB Robotics (official product pages), accessed 5 October 2026. Original text: “High precision with repeatability of ±0.02 mm”
Number of axes
7
Claimed by the manufacturerClaimed by the manufacturer. ABB Robotics (official product pages), accessed 26 October 2026. per arm. Original text: “IRB 14000 YuMi® Dual Arm Datasheet Specifications Dual-arm design with 7 axes per arm for human-like dexterity”

Per arm.

Not disclosed: price, height, weight, battery life, availability in France
Specifications

7 verified specifications · updated on · Written with AI · checked against the sources

YuMi IRB 14000, specifications and levels of evidence
SpecificationYuMi IRB 14000Level of evidence
Payload500 gClaimed by the manufacturerClaimed by the manufacturer. ABB Robotics (official product pages), accessed 5 October 2026. per arm. Original text: “Payload capacity of 0.5 kg per arm, suitable for delicate tasks”
Industrial robot typeCobotClaimed by the manufacturerClaimed by the manufacturer. ABB Robotics (official product pages), accessed 5 October 2026. Original text: “Dual-Arm Collaborative Robot for Precise AssemblyThe YuMi IRB 14000 was developed”
Reach55.9 cmClaimed by the manufacturerClaimed by the manufacturer. ABB Robotics (official product pages), accessed 5 October 2026. per arm. Original text: “Reach of 0.559 m per arm, optimized for small parts assembly”
Repeatability± 0.02 mmClaimed by the manufacturerClaimed by the manufacturer. ABB Robotics (official product pages), accessed 5 October 2026. Original text: “High precision with repeatability of ±0.02 mm”
Maximum tool speed5.4 km/hClaimed by the manufacturerClaimed by the manufacturer. ABB Robotics (official product pages), accessed 5 October 2026. maximum linear TCP speed. Original text: “Maximum linear TCP speed of 1.5 m/s for efficient operations”
Number of axes7Claimed by the manufacturerClaimed by the manufacturer. ABB Robotics (official product pages), accessed 26 October 2026. per arm. Original text: “IRB 14000 YuMi® Dual Arm Datasheet Specifications Dual-arm design with 7 axes per arm for human-like dexterity”
MountingTableClaimed by the manufacturerClaimed by the manufacturer. ABB Robotics (official product pages), accessed 19 October 2026. Original text: “Mounting Table Environment”

Do you have a source? Tell us

Claimed by the manufacturerReported by a news outletIndependent test observed or measuredNo: confirmed absence · Not disclosed: no source

Program this robot

Verified on

Community projects

  • uynitsuj/yumi_realtime · Project independent of the manufacturer

    Licence not recognised · 28 stars · Python · Dormant, last updated 24 September 2025

    Realtime & high-frequency control interfaces for the YuMi IRB 14000 bi-manual robot arm including manual tele-operation and autonomous Diffusion Policy controllers

Figures read on GitHub on 15 November 2026.

News about this robot

No news about YuMi IRB 14000 yet. Follow the profile to hear about the next story.Follow this robot

Comparable robots

See every robot in this category
A0509

A0509

Doosan Robotics · Robot arm

Industry and production

Price not disclosed

ClaimedAnnounced only
A0912

A0912

Doosan Robotics · Robot arm

Industry and production

Price not disclosed

ClaimedAnnounced only
AR Series
Illustration of the Signal mannequin, not a photo of the robotIllustration, not a photo of the robot

AR Series

Yaskawa · Robot arm

Industry and production

Price not disclosed

ClaimedAnnounced onlyBasic profile
AR1440
Illustration of the Signal mannequin, not a photo of the robotIllustration, not a photo of the robot

AR1440

Yaskawa · Robot arm

Industry and production

Price not disclosed

ClaimedAnnounced only
Cite this profile

Plain citation

“YuMi IRB 14000”, Vuntum, updated 4 November 2026, https://vuntum.com/en/robots/abb-yumi-irb-14000

APA format

Vuntum. (2026, November 4). YuMi IRB 14000. https://vuntum.com/en/robots/abb-yumi-irb-14000

Embed this badge

Vuntum profile: YuMi IRB 14000

To show on your site how many sourced values this profile holds, linking back to it.

HTML code

<a href="https://vuntum.com/en/robots/abb-yumi-irb-14000"><img src="https://vuntum.com/badge/abb-yumi-irb-14000.svg?lang=en" alt="Vuntum profile: YuMi IRB 14000" height="20"></a>

Shields.io address (README, other styles)

https://img.shields.io/endpoint?url=https%3A%2F%2Fvuntum.com%2Fapi%2Fv1%2Frobots%2Fabb-yumi-irb-14000%2Fbadge%3Flang%3Den

YuMi IRB 14000 · ABB Robotics · Vuntum