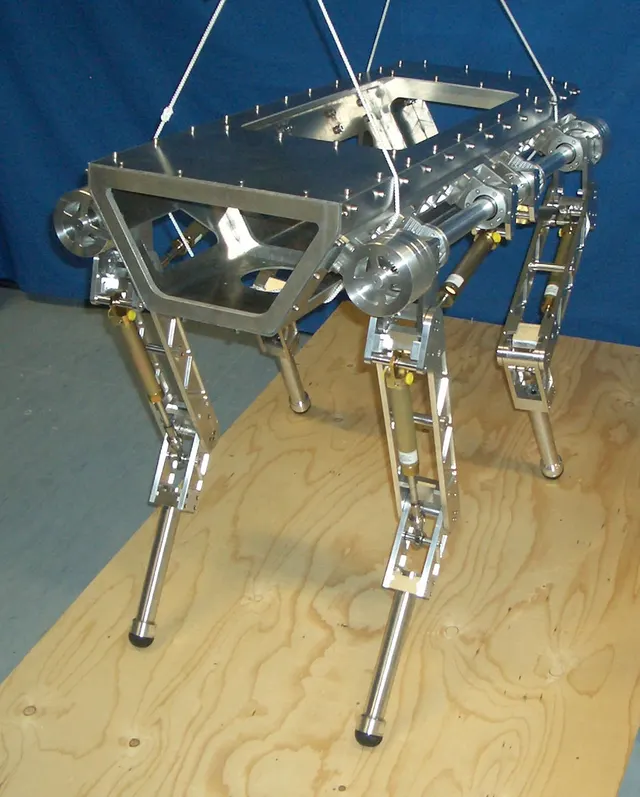
| Height | 98 cmOriginal text: “0.98m” | Claimed by the manufacturerClaimed by the manufacturer. Istituto Italiano di Tecnologia (pages produit officielles), accessed 28 September 2026. legs fully extended. Original text: “Dimensions (fully stretched legs): 1.0m x 0.5m x 0.98m (Length x Width x Height)” |
|---|
| Width | 50 cmOriginal text: “0.5m” | Claimed by the manufacturerClaimed by the manufacturer. Istituto Italiano di Tecnologia (pages produit officielles), accessed 28 September 2026. legs fully extended. Original text: “Dimensions (fully stretched legs): 1.0m x 0.5m x 0.98m (Length x Width x Height)” |
|---|
| Depth | 1 mOriginal text: “1.0m” | Claimed by the manufacturerClaimed by the manufacturer. Istituto Italiano di Tecnologia (pages produit officielles), accessed 28 September 2026. legs fully extended; listed as Length. Original text: “Dimensions (fully stretched legs): 1.0m x 0.5m x 0.98m (Length x Width x Height)” |
|---|
| Weight | 80 kg | Claimed by the manufacturerClaimed by the manufacturer. Istituto Italiano di Tecnologia (pages produit officielles), accessed 28 September 2026. external hydraulic power supply. Original text: “Weight: 80kg (external hydraulic power supply)” |
|---|
| Maximum speed | 2 m/s | Claimed by the manufacturerClaimed by the manufacturer. Istituto Italiano di Tecnologia (pages produit officielles), accessed 28 September 2026. up to; walk, trot and run. Original text: “Walk, trot and run up to 2m/s” |
|---|
| Locomotion type | QuadrupedOriginal text: “Hydraulically actuated Quadruped robot” | Claimed by the manufacturerClaimed by the manufacturer. Istituto Italiano di Tecnologia (pages produit officielles), accessed 28 September 2026. Original text: “HyQ is a fully torque-controlled Hydraulically actuated Quadruped robot” |
|---|
| Degrees of freedom | 12 count | Claimed by the manufacturerClaimed by the manufacturer. Istituto Italiano di Tecnologia (pages produit officielles), accessed 28 September 2026. Original text: “Number of active DOF: 12 hydraulic actuators” |
|---|
| Camera | Yes, stereo cameraOriginal text: “stereo camera” | Claimed by the manufacturerClaimed by the manufacturer. Istituto Italiano di Tecnologia (pages produit officielles), accessed 28 September 2026. Original text: “Onboard sensors: High-resolution relative+absolute position and torque sensors on each joint, inertial measurement unit (IMU), hydraulic system pressure, stere…” |
|---|
| LiDAR | Yes, LIDAROriginal text: “LIDAR” | Claimed by the manufacturerClaimed by the manufacturer. Istituto Italiano di Tecnologia (pages produit officielles), accessed 28 September 2026. Original text: “Onboard sensors: High-resolution relative+absolute position and torque sensors on each joint, inertial measurement unit (IMU), hydraulic system pressure, stere…” |
|---|
| Onboard compute | PC104 Pentium, real-time Linux (Xenomai) with multi-I/O boards | Claimed by the manufacturerClaimed by the manufacturer. Istituto Italiano di Tecnologia (pages produit officielles), accessed 28 September 2026. Original text: “Onboard computer: PC104 Pentium, real-time Linux (Xenomai) with multi-I/O boards” |
|---|