Other form · Research and development
Sharpa W01
Status: Announced only · Proof: statements only. Vuntum has not yet recorded any proof of a demonstration or a sale. See the rule
Use cases: Education and programming · Research and development
Setting: School and laboratory · For: Research and education · Maker based in Singapore
by Sharpa
Key facts
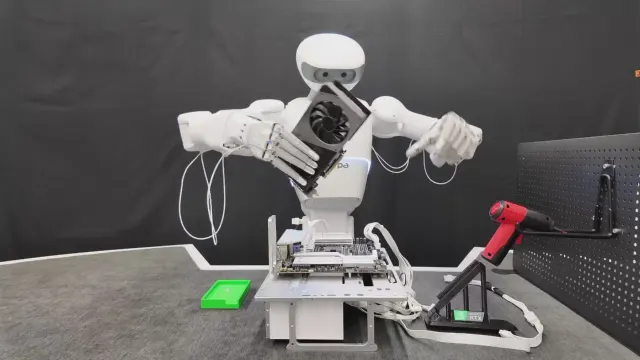
The Sharpa W01 is a five-fingered hand made by Sharpa, intended for research and education. It weighs 1.3 kg. It can be simulated in Isaac SimNVIDIA’s robotics simulator, built on the OpenUSD scene format, used to test robots, generate synthetic data and train policies by reinforcement learning.Read the glossary entry and MuJoCoA general-purpose physics engine, whose name stands for Multi-Joint dynamics with Contact, designed to simulate articulated structures in contact with their environment quickly and accurately.Read the glossary entry, is ROS 2An open-source set of libraries and tools for developing robot software, from sensor drivers to navigation algorithms.Read the glossary entry compatible, and has the official Sharpa Wave SDK.
- Weight
- 1.3 kg
- Claimed by the manufacturerClaimed by the manufacturer. Sharpa (official product pages), accessed 3 October 2026. Original text: “Weight 1.3 kg”
- Hand type
- 5-finger hand
- Claimed by the manufacturerClaimed by the manufacturer. Sharpa (official product pages), accessed 3 October 2026. Original text: “Sharpa Wave is a human-scale, five-finger dexterous hand with 22 active DoF”
- ROS compatibility
- ROS 2
- Claimed by the manufacturerClaimed by the manufacturer. Sharpa (official product pages), accessed 3 October 2026. Original text: “Integrate with ROS 2 Simulate in MuJoCo and Isaac Sim Deploy with SharpaPilot SDK”
- Official SDK
- Sharpa Wave SDK
- Claimed by the manufacturerClaimed by the manufacturer. Sharpa (official product pages), accessed 3 October 2026. Original text: “Development Toolkit Sharpa Wave SDK”
Not disclosed: price, height, battery life, availability in France