FREN
Menu

Robots / Humanoid / Unitree G1

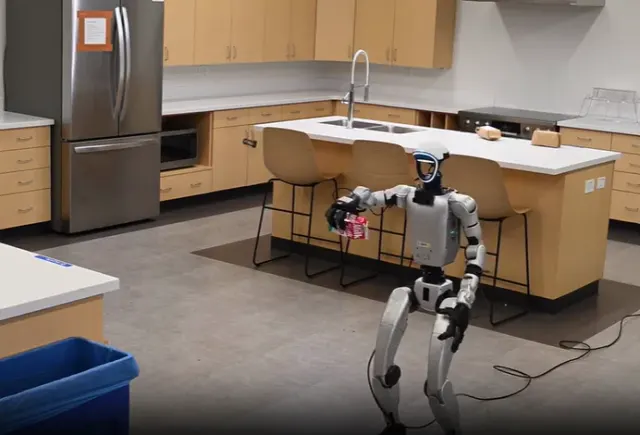
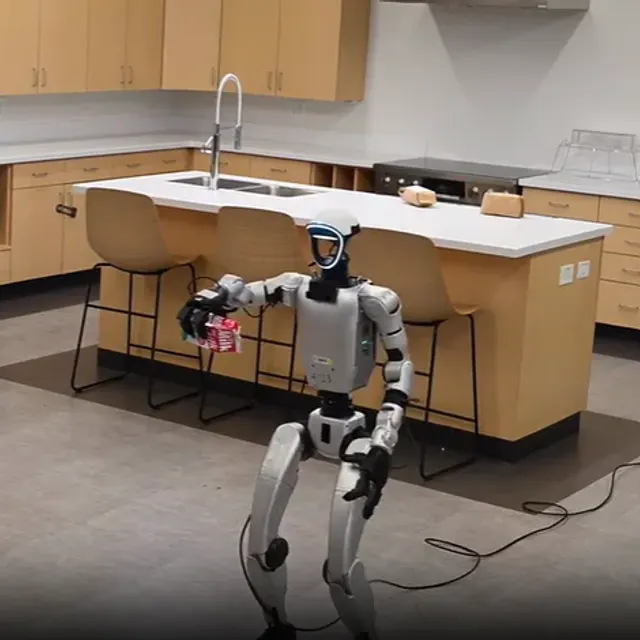
Unitree G1, photo
Photo: heise online · original article

Humanoid · Research and development

Unitree G1

Reality level : Demo · Proof: at least one value resting on a demonstration or a test, with no sale observed. See the rule

Useful for: Education and programming · Research and development

by Unitree Robotics · 2 versions: G1 and G1 EDU

Key facts

The Unitree G1 is a humanoid robot from Unitree Robotics, intended for research and education. It weighs about 35 kg, battery included, and carries about 2 kg per arm. Its recommended price in the US is 13,500 USD, excluding taxes and delivery fees.

Recommended price
13,500 USD
Claimed by the manufacturerClaimed by the manufacturer. Unitree Robotics (pages produit officielles), accessed 28 September 2026. G1, Tax and shipping cost excluded. Original text: “Price(Tax and Shipping cost excluded)US $13.5K”

Version G1, United States market. Tax and shipping cost excluded.

Weight
≈ 35 kg
Claimed by the manufacturerClaimed by the manufacturer. Unitree Robotics (pages produit officielles), accessed 30 September 2026. G1, approximate, battery included (带电池). Original text: “带电池重量约35kg”

Version G1. approximate, battery included (带电池).

Payload
≈ 2 kg (G1 EDU: ≈ 3 kg)
Claimed by the manufacturerClaimed by the manufacturer. Unitree Robotics (pages produit officielles), accessed 30 September 2026. G1, maximum load per arm, approximate; varies greatly depending on arm posture. Original text: “手臂最大负载【2】约2Kg约3Kg”

Version G1. maximum load per arm, approximate; varies greatly depending on arm posture.

Teleoperation
Yes
ReportedReported. Numerama (Robots), published 25 August 2026. Remote control included. Original text: “ils sont livrés avec une télécommande et peuvent exécuter les mouvements déjà intégrés par Unitree”

Remote control included.

Not disclosed height, battery life, availability in France
Overview

The Unitree G1 is a humanoid robot from Unitree Robotics, a Chinese manufacturer. It is aimed at research and teaching, with two stated uses: education and programming on one hand, research and development on the other.

According to the manufacturer, the G1 weighs around 35 kg, battery included. Each arm carries a maximum load of around 2 kg, a figure that varies widely with arm posture; the G1 EDU version goes up to around 3 kg per arm. The robot is fitted with a camera, a lidar and a microphone. Its onboard computer is a high-performance eight-core processor, presented as baseline computing power for both the G1 and the G1 EDU.

On the software side, the manufacturer says the G1 can be simulated in MuJoCo using its own simulator, based on its development kit and on MuJoCo, in the C++ version; the Python version of the simulator does not support the G1. ROS compatibility is through ros2, with the manufacturer's official package, which provides a low-level control example for the G1. Teleoperation is possible, but the system was designed by researchers, not by the manufacturer: it controls the upper body in XR and locomotion with pedals.

According to the manufacturer, the recommended retail price is 85,000 CNY including tax on the Chinese market; for the G1 EDU version, the price must be requested from sales. On the US market it is 13,500 USD, excluding taxes and delivery fees, and this is the starting price of the base version.

Among similar robots, Booster T1 weighs 30 kg and its computer is a Nvidia AGX Orin GPU rated at 200 TOPS, whereas the G1 lists an eight-core processor. AGIBOT X2 is given as 35 kg, like the G1, but has no lidar. Unitree H1 has a lidar, a camera, MuJoCo simulation and ros2 compatibility, all of which it shares with the G1. Reachy 2 also has a lidar and MuJoCo simulation.

Specifications

8 verified specifications · updated on

Unitree G1, specifications and levels of evidence
SpecificationG1G1 EDULevel of evidence
Manufacturer suggested priceG113,500 USDOriginal text: “US $13.5K”G1 EDUNot disclosedClaimed by the manufacturerClaimed by the manufacturer. Unitree Robotics (pages produit officielles), accessed 30 September 2026. G1, price including tax (含税); G1 EDU version: price on request (联系销售). Original text: “售价(含税)¥8.5万元联系销售”
WeightG1≈ 35 kgOriginal text: “约35kg”G1 EDUNot disclosedReported · TechRadarReported. TechRadar (Robotics), published 5 June 2026. Original text: “At 4 feet tall and just 77lbs, perhaps Unitree and those who buy it don't consider it much of a threat.”Reported · NumeramaReported. Numerama (Robots), published 25 August 2026. Original text: “Poids27 kg29 kg35 kg”Claimed by the manufacturerClaimed by the manufacturer. Unitree Robotics (pages produit officielles), accessed 30 September 2026. G1, approximate, battery included (带电池). Original text: “带电池重量约35kg”
PayloadG1≈ 2 kgOriginal text: “约2Kg”G1 EDU≈ 3 kgOriginal text: “约3Kg”Claimed by the manufacturerClaimed by the manufacturer. Unitree Robotics (pages produit officielles), accessed 30 September 2026. G1, maximum load per arm, approximate; varies greatly depending on arm posture. Original text: “手臂最大负载【2】约2Kg约3Kg”
Teleoperation supportedYesOriginal text: “livrés avec une télécommande”Reported · NumeramaReported. Numerama (Robots), published 25 August 2026. Remote control included. Original text: “ils sont livrés avec une télécommande et peuvent exécuter les mouvements déjà intégrés par Unitree”Claimed by the manufacturerClaimed by the manufacturer. arXiv (cs.RO, robotique), published 2 October 2026. Teleoperation system designed by researchers, not by the manufacturer: upper-body control in XR, pedal-based locomotion. Original text: “We present a teleoperation system that enables a single operator to perform construction tasks on a Unitree G1 humanoid, combining extended reality (XR) based …”
CameraYes, Research setup HomeBody (Stanford/Caltech) with GPT AstraOriginal text: “caméra de profondeur”Reported · NumeramaReported. Numerama (Robots), published 25 August 2026. Original text: “PerceptionCaméra monoculaireCaméra binoculaireLiDAR 3D et caméra de profondeur”Reported · heise onlineReported. heise online (Roboter), published 28 September 2026. Original text: “Bei der Erkundung scannt er die Umgebung unter anderem mithilfe einer Kamera und Lidar.”Claimed by the manufacturerClaimed by the manufacturer. Unitree Robotics (pages produit officielles), accessed 30 September 2026. Original text: “感知传感器深度相机+3D激光雷达”
MicrophoneYes, 4-microphone arrayOriginal text: “4麦克风阵列有有”Claimed by the manufacturerClaimed by the manufacturer. Unitree Robotics (pages produit officielles), accessed 30 September 2026. Original text: “4麦克风阵列有有”
LiDARYes, Research setup HomeBody (Stanford/Caltech) with GPT AstraOriginal text: “LiDAR 3D”Reported · NumeramaReported. Numerama (Robots), published 25 August 2026. Original text: “LiDAR 3D et caméra de profondeur”Reported · heise onlineReported. heise online (Roboter), published 28 September 2026. Original text: “Bei der Erkundung scannt er die Umgebung unter anderem mithilfe einer Kamera und Lidar.”Claimed by the manufacturerClaimed by the manufacturer. Unitree Robotics (pages produit officielles), accessed 30 September 2026. Original text: “感知传感器深度相机+3D激光雷达”
Onboard compute8-core high-performance CPUClaimed by the manufacturerClaimed by the manufacturer. Unitree Robotics (pages produit officielles), accessed 30 September 2026. Original text: “基础算力8核高性能CPU”

Do you have a source? Tell us

Claimed by the manufacturerReported by a news outletIndependent test observed or measuredNo: confirmed absence · Not disclosed: no source

Program this robot

Verified on

Programmable: yes (ROS 2).

Accessible from the advanced level. To start: ROS.

ROS 2

ROS compatibility
ROS 2 Claimed by the manufacturerClaimed by the manufacturer. Unitree Robotics (pages produit officielles), published 2 July 2026. Official unitree_ros2 package from the manufacturer, which provides a low-level control example for the G1; the page's introduction mentions only Go2, B2 and H1. Original text: “g1/lowlevel/g1_low_level_example: Low level control for G1 - h1-2/lowlevel/low_level_ctrl_hg: Low level control for H1-2 - low_level_ctrl: Low level control fo…”

Simulation

MuJoCo simulation
Yes Claimed by the manufacturerClaimed by the manufacturer. Unitree Robotics (pages produit officielles), published 7 September 2026. unitree_mujoco simulator (based on unitree_sdk2 and MuJoCo), C++ version; the Python configuration does not list g1. Original text: “# Robot name loaded by the simulator # "go2", "b2", "b2w", "h1", "go2w", "g1", "h2", "as2"”

Official code

  • unitreerobotics/unitree_sdk2 · Official SDK

    BSD-3-Clause · 1,387 stars · C++ · Active, last updated 21/09/2026

    Unitree robot sdk version 2. https://support.unitree.com/home/zh/developer

  • unitreerobotics/unitree_sdk2_python · Official SDK

    BSD-3-Clause · 815 stars · Python · Active, last updated 21/09/2026

    Python interface for unitree sdk2

  • unitreerobotics/unitree_ros2 · ROS 2 packages

    BSD-3-Clause · 850 stars · C++ · Slowing down, last updated 02/07/2026

  • unitreerobotics/unitree_ros · Simulation model

    BSD-3-Clause · 1,579 stars · C++ · Active, last updated 30/09/2026

  • unitreerobotics/unitree_rl_lab · Simulation model

    Apache-2.0 · 1,377 stars · Python · Slowing down, last updated 25/05/2026

    This is a repository for reinforcement learning implementation for Unitree robots, based on IsaacLab.

See the 3 other repositories
  • unitreerobotics/unitree_mujoco · Simulation model

    BSD-3-Clause · 1,228 stars · C++ · Active, last updated 07/09/2026

  • unitreerobotics/unitree_lerobot · Other official repository

    Licence not recognised automatically · 771 stars · Python · Slowing down, last updated 25/05/2026

    The unitree_il_lerobot open-source project is a modification of the LeRobot open-source training framework, enabling the training and testing of data collected using the dual-arm dexterous hands of Unitree's G1 robot.

  • unitreerobotics/kinect_teleoperate · Other official repository

    BSD-3-Clause · 122 stars · C · Dormant, last updated 13/08/2024

    This repository implements teleoperation of the Unitree humanoid robot H1 / G1 using Azure Kinect DK camera.

Figures read on GitHub on 02/10/2026.

Community projects

  • abizovnuralem/go2_omniverse · Project independent of the manufacturer

    BSD-2-Clause · 1,079 stars · Python · Slowing down, last updated 01/07/2026

    Unitree Go2, Unitree G1 support for Nvidia Isaac Lab (Isaac Gym / Isaac Sim)

  • deepglint/FAST_LIO_LOCALIZATION_HUMANOID · Project independent of the manufacturer

    Licence not recognised automatically · 917 stars · C++ · Slowing down, last updated 06/01/2026

    Localization by LiDAR for Humanoid(like Unitree G1)

  • linden713/humanoid_amp · Project independent of the manufacturer

    BSD-3-Clause · 470 stars · Python · Slowing down, last updated 18/10/2025

    Isaac Lab Humanoid AMP for Unitree G1

  • hucebot/g1pilot · Project independent of the manufacturer

    BSD-3-Clause · 287 stars · Python · Slowing down, last updated 12/06/2026

    ROS2 Package to work with the robot G1 from unitree

  • NPCLEI/KungFuAthleteBot · Project independent of the manufacturer

    MIT · 283 stars · Python · Active, last updated 16/09/2026

    A highly dynamic martial arts motion dataset (848 samples, Ground/Jump subsets) for humanoid robots, with GMR retargeting, height adjustment, and RL training pipeline (PPO & FastSAC) for Unitree G1, featuring fall recovery and sim-to-real deployment.

See the 8 other repositories
  • mujocolab/g1_spinkick_example · Project independent of the manufacturer

    Apache-2.0 · 250 stars · Python · Slowing down, last updated 21/02/2026

    Train a Unitree G1 humanoid to perform a double spin kick using mjlab

  • Sentdex/unitree_g1_vibes · Project independent of the manufacturer

    MIT · 207 stars · Python · Dormant, last updated 22/07/2025

  • jiachengliu3/OpenWBC · Project independent of the manufacturer

    Licence not recognised automatically · 175 stars · C++ · Slowing down, last updated 17/02/2026

    VR-based Robot Teleoperation and Data Collection System for Humanoid Whole-Body VLA (Unitree G1)

  • yueruyin/robot-unitree-g1 · Project independent of the manufacturer

    Apache-2.0 · 131 stars · Python · Slowing down, last updated 02/12/2025

    基于mujoco仿真环境对unitree g1机器操作的研究和学习

  • HansZ8/unitree_cpp · Project independent of the manufacturer

    Licence not recognised automatically · 93 stars · C++ · Slowing down, last updated 22/05/2026

    Free your Unitree G1 from cable connection

  • mrzuang/GRIT_teleop_deploy · Project independent of the manufacturer

    Licence not recognised automatically · 89 stars · Python · Active, last updated 02/09/2026

    This repository provides Unitree G1 deployment code for GRIT v0.0.1, a whole-body motion-tracking control algorithm for humanoid robots.

  • yifeichen2024/G1_deploy · Project independent of the manufacturer

    Licence not recognised automatically · 79 stars · Python · Dormant, last updated 24/07/2025

    Deploy the policy on the unitree G1 robot

  • shanpenghui/RoboMimicDeploy_G1 · Project independent of the manufacturer

    Licence not recognised automatically · 68 stars · Python · Dormant, last updated 21/08/2025

    RoboMimicDeploy_G1 is a policy deployment and control framework for the Unitree G1 robot, supporting both Mujoco simulation and real-time control on the physical robot.

Figures read on GitHub on 02/10/2026.

Independent tests

What others measured with the robot in their hands. A measurement keeps its conditions and does not replace the announced value: two measurements taken in different conditions cannot be compared.

Unitree G1, independent test measurements
MeasurementMeasured valueTested by
Teleoperation supportedYesConditions: Observed live during demonstrations (dance, boxing match) at the Unitree stand, hall 25, IFA Berlin; human operator with controller next to the robotIndependent test · XatakaIndependent test. Xataka (Robots), published 13 September 2026. Original text: “Absolutamente todos los robots que pude ver en IFA estaban siendo controlados por personas que llevaban un mando en las manos.”

Proof log

The dated events Vuntum found for this robot, newest first, each with its source. A line appears only if its date and its source page are known.

4 proofs: 4 from independent sources, 0 from the maker, 0 from other sources.

  1. , Reported by an independent source: 2 values on the sheet

    Independent source. Source: heise online (Roboter)

  2. , Reported by an independent source: 1 value on the sheet

    Independent source. Source: Xataka (Robots)

  3. , Reported by an independent source: 17 values on the sheet

    Independent source. Source: Numerama (Robots)

  4. , Reported by an independent source: 1 value on the sheet

    Independent source. Source: TechRadar (Robotics)

News about this robot

All news

Comparable robots

See every robot in this category
AGIBOT X2

AGIBOT X2

AGIBOT · Humanoid

Education and programming · Research and development

Price not disclosed

ClaimedPaper announcement
ASIMO

ASIMO

Honda · Humanoid

Research and development

Price not disclosed

ClaimedPaper announcement
Booster K1

Booster K1

Booster Robotics · Humanoid

Research and development

Price not disclosed

ClaimedPaper announcement
Hydraulic Atlas

Hydraulic Atlas

Boston Dynamics · Humanoid

Research and development

Price not disclosed

Light sheet
Cite this sheet

Plain citation

“Unitree G1”, Vuntum, updated 28 September 2026, https://vuntum.com/en/robots/unitree-g1

APA format

Vuntum. (2026, September 28). Unitree G1. https://vuntum.com/en/robots/unitree-g1

Embed this badge

Vuntum sheet: Unitree G1

To show on your site how many sourced values this sheet holds, linking back to it.

HTML code

<a href="https://vuntum.com/en/robots/unitree-g1"><img src="https://vuntum.com/badge/unitree-g1.svg?lang=en" alt="Vuntum sheet: Unitree G1" height="20"></a>

Shields.io address (README, other styles)

https://img.shields.io/endpoint?url=https%3A%2F%2Fvuntum.com%2Fapi%2Fv1%2Frobots%2Funitree-g1%2Fbadge%3Flang%3Den