Listed

, home
FREN

Robots / Mobile manipulator / Stretch 4

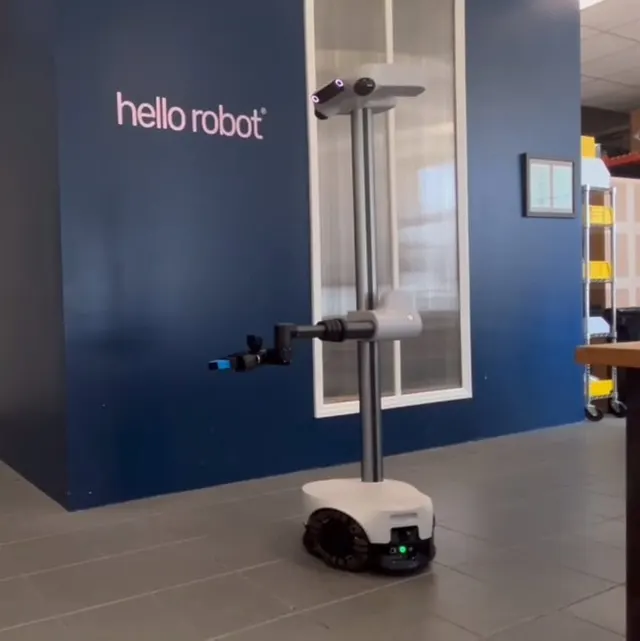
Stretch 4, official image from Hello Robot
© Hello Robot · official image · original page

Mobile manipulator · Research and development

Stretch 4

Status: Deployed · Proof: availability read at the source, with a shipping commercial status. See the rule

Use cases: Education and programming · Research and development

Setting: School and laboratory · For: Research and education · Maker based in United States

by Hello Robot

Key facts

The Stretch 4 is a mobile manipulator from Hello Robot, intended for research and education. It stands 160 cm tall and runs for 8 h (light CPU load). It is on sale, with a A sensor that measures distances by emitting laser pulses and timing the return of the reflected light.Read the glossary entry and a camera.

Height
1.6 m
Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), accessed 28 September 2026. Original text: “Height / Footprint160 cm Height / 45 cm Diameter”
Weight
46 kg
Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), accessed 28 September 2026. Original text: “Total Weight46 kg / 33 kg ballast off for transport”
Battery runtime
8 h
Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), accessed 7 October 2026. light CPU load. Original text: “Runtime8 hours (Light CPU load)”

Light CPU load.

Payload
2.5 kg
Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), accessed 28 September 2026. Arm extended. Original text: “Payload (Arm extended)2.5 kg”

Arm extended.

Not disclosed: price, availability in France
Overview

Stretch 4 is a mobile manipulator from Hello Robot. It is intended for research and education, including programming. According to the manufacturer, it moves on wheels.

According to the manufacturer, the robot stands 160 cm tall. Its telescopic arm has a reach of 52 cm: this is the horizontal extension beyond the base, at maximum extension. The hand is modular. For perception, the manufacturer lists a camera and a LiDAR. The onboard computer is a NUC.

Also according to the manufacturer, Stretch 4 navigates autonomously using a ROS 2 navigation stack. Teleoperation is possible. The manufacturer lists a public SDK, and an official SDK exists. A Python API is available through a package in the Stretch 4 ROS 2 repository. The robot is compatible with ROS 2, and the Jazzy version is supported. For simulation, the manufacturer provides an official 3D model, and the robot can be simulated in MuJoCo.

RB-Y1 also moves on wheels and has a public SDK, like Stretch 4. Its height is given as 1,400 mm, compared with 160 cm for Stretch 4 according to the manufacturer. Its onboard computer is a real-time control PC (Robot PC), separate from the user's application PC (User PC), whereas Stretch 4 carries a NUC. For more detail, compare Stretch 4 and RB-Y1.

TIAGo shares with Stretch 4 its wheeled locomotion, the LiDAR and the official 3D model for simulation. The details are in the comparison between Stretch 4 and TIAGo.

Specifications

14 verified specifications · updated on · Written with AI · checked against the sources

Stretch 4, specifications and levels of evidence
SpecificationStretch 4Level of evidence
AvailabilityAvailableOriginal text: “Stretch 4 is available now!”Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), accessed 7 October 2026. Original text: “Stretch 4 is available now!”
Height1.6 mOriginal text: “160 cm Height”Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), accessed 28 September 2026. Original text: “Height / Footprint160 cm Height / 45 cm Diameter”
Weight46 kgClaimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), accessed 28 September 2026. Original text: “Total Weight46 kg / 33 kg ballast off for transport”
Battery runtime8 hOriginal text: “8 hours”Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), accessed 7 October 2026. light CPU load. Original text: “Runtime8 hours (Light CPU load)”
Locomotion typeWheeledOriginal text: “triangular holonomic omnibase”Reported · TechCrunchReported. TechCrunch (Robotics), published 22 September 2026. Original text: “Stretch 4 doesn’t need legs to get around. It rolls.”Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 16 July 2026. Original text: “Stretch SE4 has a triangular holonomic omnibase — three holonomic closed-loop stepper motors each driving one omnidirectional wheel.”
Degrees of freedom3Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 16 July 2026. wrist only (yaw, pitch, roll). Original text: “Stretch 4 has a 3-DOF dexterous wrist (yaw, pitch, roll)”
Payload2.5 kgClaimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), accessed 28 September 2026. Arm extended. Original text: “Payload (Arm extended)2.5 kg”
Reach55 cmOriginal text: “55 cm + 6 cm wrist”Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), accessed 7 October 2026. plus 6 cm for the wrist. Original text: “Reach55 cm + 6 cm wrist”
Hand typeModularOriginal text: “custom end-of-arm tools”Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 2 October 2026. Original text: “Stretch 4 supports dynamic user-defined custom end-of-arm tools.”
Autonomous navigationYes, Navigation stack built on Nav2Original text: “Navigation stack built on Nav2”Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 1 October 2026. ROS 2 navigation stack stretch_nav2. Original text: “Navigation stack built on Nav2”
Teleoperation supportedYes, Web teleopClaimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 30 October 2026. Commands sent to the real robot from the simulation over the network; digital-twin extension reserved for Linux.. Original text: “Mirror motion between the sim and a real Stretch 4 over the network. Commands issued in sim are forwarded to the robot as the same `RobotClient` command, and t…”
CameraYes, head cameras / gripper cameraOriginal text: “head cameras / gripper camera”Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 1 October 2026. Original text: “for the head cameras and `ros2 launch stretch_core gripper_camera.launch.py` for the gripper camera.”
LiDARYes, The two lidars are mounted on the robotOriginal text: “The two lidars are mounted on the robot”Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 25 August 2026. Original text: “The two lidars are mounted on the robot and can see its own base”
Onboard computeNUCClaimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 16 July 2026. Original text: “a background stretch_body_server process running a 100 Hz control loop on the NUC”

Do you have a source? Tell us

Claimed by the manufacturerReported by a news outletIndependent test observed or measuredNo: confirmed absence · Not disclosed: no source

Program this robot

Verified on

Programmable: yes (Python, ROS 2).

Accessible from the intermediate level. To start: Python SDK. To go further: ROS.

SDK and languages

Public SDK
Yes Reported · TechCrunchReported. TechCrunch (Robotics), published 22 September 2026. Original text: “comes with a full-stack, open source software platform for researchers and developers working on robotics and embodied AI”Yes Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), accessed 28 September 2026. Original text: “Open source ROS 2 and Python SDK”Yes Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 2 October 2026. Original text: “python3 -m pip install -U hello-robot-stretch4-body”Yes Reported · TechCrunchReported. TechCrunch (Robotics), published 22 September 2026. Original text: “The company says the new generation was shaped by six years of customer feedback and comes with a full-stack, open source software platform for researchers and…”Yes Reported · TechCrunchReported. TechCrunch (Robotics), published 22 September 2026. Original text: “The company says the new generation was shaped by six years of customer feedback and comes with a full-stack, open source software platform for researchers and…”Yes Reported · TechCrunchReported. TechCrunch (Robotics), published 22 September 2026. Original text: “comes with a full-stack, open source software platform for researchers and developers working on robotics and embodied AI”Yes Reported · TechCrunchReported. TechCrunch (Robotics), published 22 September 2026. Original text: “The company says the new generation was shaped by six years of customer feedback and comes with a full-stack, open source software platform for researchers and…”Yes Reported · TechCrunchReported. TechCrunch (Robotics), published 22 September 2026. Original text: “comes with a full-stack, open source software platform for researchers and developers working on robotics and embodied AI”
Official SDK
stretch4_body Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 16 July 2026. Original text: “The stretch4_body package is pre-installed on every Stretch SE4.”,stretch4_body Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 2 October 2026. Original text: “The `stretch4_body` repository contains the core Python software stack that allows developers to interact with the hardware of Stretch 4 robots.”
Python API
Yes Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 1 October 2026. stretch_python_bridge package from the Stretch 4 ROS 2 repository. Original text: “A high-level Python API that abstracts away rclpy”Yes Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 2 October 2026. Original text: “The `stretch4_body` repository contains the core Python software stack that allows developers to interact with the hardware of Stretch 4 robots.”Yes Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), accessed 28 September 2026. Original text: “Open source ROS 2 and Python SDK”Yes Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 16 July 2026. Original text: “Python (Stretch 4 Body) is the low-level direct interface to the robot hardware.”

ROS 2

ROS compatibility
ROS 2 Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 19 September 2026. robot description (URDF) package exportable for use in ROS2. Original text: “exporting for use in other programs (e.g. ROS2, pinocchio)”ROS 2 Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 1 October 2026. Original text: “This repository holds ROS 2 Jazzy packages for the Stretch 4 mobile manipulator from Hello Robot Inc.”ROS 2 Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), accessed 28 September 2026. Original text: “Open source ROS 2 and Python SDK”ROS 2 Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 1 October 2026. ROS2 simulation package stretch_simulation (manufacturer's stretch4_ros2 repository). Original text: “You can use this simulation in ROS2 using the [`stretch_simulation` package]”ROS 2 Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 16 July 2026. Original text: “Stretch SE4 ships with ROS 2 Jazzy and a full driver stack.”
Supported ROS 2 distributions
Jazzy Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 16 July 2026. Original text: “Stretch SE4 ships with ROS 2 Jazzy and a full driver stack.”Jazzy Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 1 October 2026. Original text: “This repository holds ROS 2 Jazzy packages for the Stretch 4 mobile manipulator from Hello Robot Inc.”

Simulation

Official simulation model
Yes Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 1 October 2026. Original text: “Stretch 4 MJCF and URDF”Yes Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 1 October 2026. Original text: “Simulation of Stretch 4, built on [Stretch4 Mujoco]”
MuJoCo simulation
Yes Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 1 October 2026. Original text: “This repo provides a simulation stack for Stretch 4, built on [MuJoCo]”Yes Claimed by the manufacturerClaimed by the manufacturer. Hello Robot (official product pages), published 1 October 2026. Original text: “Simulation of Stretch 4, built on [Stretch4 Mujoco]”

Official code

  • hello-robot/stretch4_body · Official SDK

    Licence not recognised · 2 stars · Python · Active, last updated 13 November 2026

    Python API for the Stretch 4 robot

  • hello-robot/stretch4_ros2 · ROS 2 packages

    Licence not recognised · 5 stars · Python · Active, last updated 12 November 2026

    ROS 2 packages for the Stretch 4 robot

  • hello-robot/stretch4_mujoco · Simulation model

    BSD-3-Clause-Clear · 5 stars · Python · Active, last updated 6 November 2026

    A simulation stack for Stretch 4, built on MuJoCo.

  • hello-robot/stretch4_urdf · Simulation model

    Licence not recognised · 4 stars · Python · Active, last updated 6 November 2026

    URDF for the Stretch 4 mobile manipulator from Hello Robot Inc.

  • hello-robot/stretch4_examples · Official examples

    MIT · 0 stars · Python · Slowing down, last updated 7 July 2026

    Example snippets of code showing how to jog joints, read sensors, and more.

See the 15 other repositories
  • hello-robot/stretch4_fast_planning_demo · Official examples

    Apache-2.0 · 0 stars · Python · Active, last updated 2 November 2026

    Fast planner + obstacle avoidance for real-world reaching.

  • hello-robot/stretch4_lerobot · Official examples

    Apache-2.0 · 0 stars · Python · Active, last updated 4 November 2026

    LeRobot integration for the Hello Robot Stretch 4: record teleop demonstrations, train policies, and run them on the robot. Works with stock LeRobot commands.

  • hello-robot/stretch4_multi_teleop_demo · Official examples

    Apache-2.0 · 0 stars · Python · Active, last updated 6 October 2026

    Multi-input teleoperation to any node that listens to a sensor_msgs/Joy message

  • hello-robot/stretch4_install · Other official repository

    Licence not recognised · 5 stars · Shell · Active, last updated 13 November 2026

    Install scripts for the Stretch 4 robot from Hello Robot Inc.

  • hello-robot/stretch4_kinematics · Other official repository

    Licence not recognised · 5 stars · Python · Active, last updated 3 November 2026

  • hello-robot/stretch4_web_teleop · Other official repository

    Apache-2.0 · 2 stars · TypeScript · Active, last updated 12 November 2026

    Accessible Web-Based Teleop Interface for Stretch 4

  • hello-robot/stretch4_compliant_gripper · Other official repository

    Apache-2.0 · 1 stars · Python · Active, last updated 21 October 2026

    Code for modeling and controlling the standard Stretch 4 compliant gripper from Hello Robot Inc.

  • hello-robot/stretch4_nav_webapp · Other official repository

    Licence not recognised · 1 stars · JavaScript · Active, last updated 20 October 2026

    Web UI for Stretch 4 mapping, map editing, and navigation

  • hello-robot/stretch4_pyhesai_wrapper · Other official repository

    Apache-2.0 · 1 stars · Python · Active, last updated 12 November 2026

    This repository provides a Python wrapper for the Hesai JT128 3D hemispherical LiDAR used by the Stretch 4 mobile manipulator from Hello Robot Inc.

  • hello-robot/inspect-robots-stretch4 · Other official repository

    Apache-2.0 · 0 stars · Python · Active, last updated 11 November 2026

    Robocurve's Inspect Robots embodiment adapter for the Hello Robot Stretch 4.

  • hello-robot/stretch4_dex_teleop · Other official repository

    Apache-2.0 · 0 stars · Python · Active, last updated 12 November 2026

    Dexterous teleoperation for the Stretch 4 from Hello Robot Inc.

  • hello-robot/stretch4_flying_gripper · Other official repository

    Apache-2.0 · 0 stars · Python · Active, last updated 3 November 2026

    This repository provides gamepad control of the robot's gripper using the gripper's coordinate system. At each time step, the controller uses a Jacobian found via a specialized URDF to set the joint velocities using weighted damped pseudo-inverse control.

  • hello-robot/stretch4_quest_teleop · Other official repository

    Apache-2.0 · 0 stars · Python · Active, last updated 27 October 2026

    Teleoperating the Hello Robot Stretch mobile manipulator using Meta Quest.

  • hello-robot/stretch4_rtabmap · Other official repository

    Apache-2.0 · 0 stars · Python · Active, last updated 13 November 2026

    ROS 2 package for lifelong mapping and navigation on Stretch 4, using GLIM for lidar-inertial odometry, RTAB-Map for global localization and map building, and Nav2 for planning and collision avoidance.

  • hello-robot/stretch4_tray · Other official repository

    Licence not recognised · 0 stars · Python · Active, last updated 4 November 2026

    Ubuntu system tray application for displaying battery level and menu for launching Stretch tools or help resources

Figures read on GitHub on 13 November 2026.

News about this robot

No news about Stretch 4 yet. Follow the profile to hear about the next story.Follow this robot

Comparable robots

See every robot in this category
COBOT MAGIC

COBOT MAGIC

AgileX Robotics · Mobile manipulator

Education and programming · Research and development +1

Price not disclosed

ClaimedAnnounced onlyTeleoperable
ELEY

ELEY

Toyota · Mobile manipulator

Education and programming · Research and development

Price not disclosed

Announced only
Galaxea R1 Pro

Galaxea R1 Pro

Galaxea Dynamics · Mobile manipulator

Education and programming · Research and development

Price not disclosed

ClaimedAnnounced only
Human Support Robot

Human Support Robot

Toyota · Mobile manipulator

Education and programming · Research and development

Price not disclosed

ClaimedAnnounced onlyTeleoperable
Cite this profile

Plain citation

“Stretch 4”, Vuntum, updated 1 November 2026, https://vuntum.com/en/robots/hello-robot-stretch-4

APA format

Vuntum. (2026, November 1). Stretch 4. https://vuntum.com/en/robots/hello-robot-stretch-4

Embed this badge

Vuntum profile: Stretch 4

To show on your site how many sourced values this profile holds, linking back to it.

HTML code

<a href="https://vuntum.com/en/robots/hello-robot-stretch-4"><img src="https://vuntum.com/badge/hello-robot-stretch-4.svg?lang=en" alt="Vuntum profile: Stretch 4" height="20"></a>

Shields.io address (README, other styles)

https://img.shields.io/endpoint?url=https%3A%2F%2Fvuntum.com%2Fapi%2Fv1%2Frobots%2Fhello-robot-stretch-4%2Fbadge%3Flang%3Den