FREN
Menu

Robots / Humanoid / Reachy 2

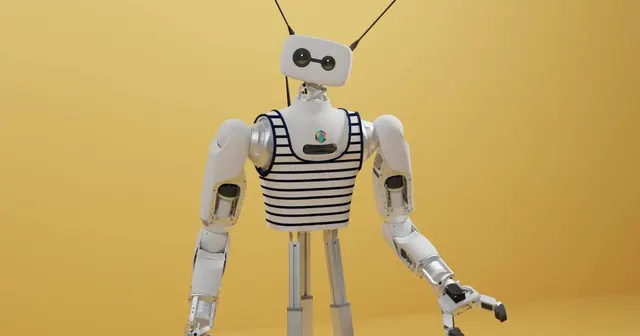
Reachy 2, photo
© Pollen Robotics · official image · original page

Humanoid · Research and development

Reachy 2

Reality level : Paper announcement · Proof: statements only, with no demonstration and no sale observed. See the rule

Useful for: Education and programming · Research and development

by Pollen Robotics

Key facts

Reachy 2 is a humanoid robot from Pollen Robotics, intended for research and education. It is equipped with a camera, a LiDAR and a microphone. Its public SDK, under the Apache 2.0 license, offers a Python API.

Teleoperation
Yes
Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), accessed 28 September 2026. VR teleoperation application. Original text: “Take control of Reachy 2 remotely using VR and our teleoperation application.”

VR teleoperation application.

Camera
Yes cameras
Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), published 26 July 2023. Original text: “access its sensors, like cameras, lidar, and microphones”
LiDAR
Yes lidar
Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), published 26 July 2023. Original text: “access its sensors, like cameras, lidar, and microphones”
Public SDK
Yes Fully open source.
Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), published 26 November 2025. Original text: “You can install the library either from Pypi, or by cloning the entire repository”

Not disclosed price, height, weight, battery life, availability in France
Overview

Reachy 2 is a humanoid robot from Pollen Robotics, a French company. It is aimed at research and education, including programming.

According to the manufacturer, Reachy 2 has a camera, a LiDAR and a microphone. It can also be teleoperated: the manufacturer mentions a VR teleoperation application.

On the software side, the manufacturer lists a public SDK under the Apache 2.0 licence and a Python API. For ROS, it mentions ros2 compatibility, provided by an SDK server repository that bridges the gRPC and ROS 2 interfaces. Also according to the manufacturer, simulation works in Gazebo, with a package from the Reachy2 Core repository, and in MuJoCo. An official 3D model is also available for simulation. Price, weight and battery life are not disclosed.

On sensors, Reachy 2 is close to Unitree G1 and Unitree H1. The G1 is listed with a camera, a microphone and a LiDAR, the H1 with a camera and a LiDAR. Booster T1 is listed with a camera and a microphone, like Reachy 2. AGIBOT X2 is listed with a microphone but no LiDAR, whereas Reachy 2 has one according to the manufacturer.

For software and simulation, Booster T1 offers, like Reachy 2, a Python API and an official 3D model for simulation, which is also found on Unitree H1. Unitree G1 and Unitree H1 can also be simulated in MuJoCo.

Specifications

4 verified specifications · updated on

Reachy 2, specifications and levels of evidence
SpecificationReachy 2Level of evidence
Teleoperation supportedYesOriginal text: “Take control of Reachy 2 remotely using VR and our teleoperation application.”Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), accessed 28 September 2026. VR teleoperation application. Original text: “Take control of Reachy 2 remotely using VR and our teleoperation application.”
CameraYes, camerasOriginal text: “cameras”Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), published 26 July 2023. Original text: “access its sensors, like cameras, lidar, and microphones”
MicrophoneYes, microphonesOriginal text: “microphones”Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), published 26 July 2023. Original text: “access its sensors, like cameras, lidar, and microphones”
LiDARYes, lidarOriginal text: “lidar”Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), published 26 July 2023. Original text: “access its sensors, like cameras, lidar, and microphones”

Do you have a source? Tell us

Claimed by the manufacturerReported by a news outletIndependent test observed or measuredNo: confirmed absence · Not disclosed: no source

Program this robot

Verified on

Programmable: yes (Python, ROS 2).

Accessible from the intermediate level. To start: Python SDK. To go further: ROS.

SDK and languages

Public SDK
Yes Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), published 26 November 2025. Original text: “You can install the library either from Pypi, or by cloning the entire repository”Yes Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), accessed 28 September 2026. Original text: “Fully open source. Teleoperated or controlled with Python.”
Python API
Yes Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), published 26 July 2023. Original text: “Full compatibility with the Python SDK”Yes Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), accessed 28 September 2026. Original text: “Teleoperated or controlled with Python.”Yes Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), published 26 July 2023. Original text: “create rich, expressive, and interactive behaviors with Python”Yes Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), published 26 November 2025. Original text: “# Python SDK for Reachy 2”
SDK licence
Apache 2.0 Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), published 26 November 2025. Original text: “[![Licence](https://img.shields.io/badge/licence-Apache%202.0-blue)](LICENSE)”

ROS 2

ROS compatibility
ROS 2 Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), published 26 July 2023. Original text: “Reachy 2 is powered by ROS 2 under the hood”ROS 2 Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), published 7 April 2026. ROS 2 packages from the Reachy2 Core repository; repository author not specified in the text. Original text: “This repository provides the core ROS 2 packages required to simulate, configure, and launch the **Reachy 2** humanoid robot.”ROS 2 Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), published 26 July 2023. Original text: “Access to the ROS 2 interface, just like with the real robot”ROS 2 Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), published 5 November 2025. SDK server repository bridging gRPC and ROS 2 interfaces. Original text: “This repository contains the ROS 2-based SDK server implementation for controlling and interfacing with **Reachy 2**, the humanoid robot developed by Pollen Ro…”ROS 2 Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), accessed 28 September 2026. Original text: “Runs on ROS 2 Humble.”

Simulation

Official simulation model
Yes Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), published 7 April 2026. URDF/xacro description in the reachy_description package. Original text: “Robot description files (URDF, meshes, xacro) for Reachy 2, used across simulation and visualization.”Yes Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), published 26 July 2023. Original text: “we provide a preconfigured Docker image that let you explore and develop for Reachy 2 on any operating system”Yes Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), published 6 January 2026. MuJoCo. Original text: “This repository contains scenes and configuration files for the robot **Reachy 2** in [MuJoCo](https://mujoco.org/).”
Gazebo simulation
Yes Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), published 26 November 2025. Original text: “The tests are based on the Gazebo simulation, so the robot must be launched in Gazebo mode when executing the tests.”Yes Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), published 7 April 2026. reachy_gazebo package from the Reachy2 Core repository. Original text: “Gazebo simulation environment for Reachy 2, including plugins and world integration.”Yes Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), published 26 July 2023. Original text: “2 platforms are currently supported for simulation:Gazebo”
MuJoCo simulation
Yes Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), published 26 July 2023. still a work in progress. Original text: “MuJoCo (still a work in progress)”Yes Claimed by the manufacturerClaimed by the manufacturer. Pollen Robotics (pages produit officielles), published 6 January 2026. Original text: “This repository contains scenes and configuration files for the robot **Reachy 2** in [MuJoCo](https://mujoco.org/).”

Official code

See the 6 other repositories
  • pollen-robotics/PincOpen · Other official repository

    CC-BY-SA-4.0 · 169 stars · Jupyter Notebook · Slowing down, last updated 16/06/2026

    A low cost and open source parallel-finger gripper, derived from Reachy 2's gripper

  • pollen-robotics/reachy2_emotions · Other official repository

    Apache-2.0 · 22 stars · Python · Slowing down, last updated 19/11/2025

  • pollen-robotics/Reachy2Teleoperation · Other official repository

    Apache-2.0 · 18 stars · C# · Slowing down, last updated 19/02/2026

    Unity app for teleoperating Reachy2

  • pollen-robotics/reachy2_qpik · Other official repository

    Apache-2.0 · 10 stars · Python · Slowing down, last updated 28/01/2026

    Quadratic Programming Inverse Kinematics control algorithm for the arms of Reachy2.

  • pollen-robotics/reachy2-docs · Other official repository

    Apache-2.0 · 8 stars · HTML · Slowing down, last updated 21/05/2026

    Documentation for Reachy 2

  • pollen-robotics/elec_relay_R2 · Other official repository

    Apache-2.0 · 0 stars · Slowing down, last updated 27/04/2026

    Relay 24V/100A + fuses to power Reachy 2

Figures read on GitHub on 02/10/2026.

News about this robot

No news about Reachy 2 yet. Follow the sheet to hear about the next story.Follow this robot

Comparable robots

See every robot in this category
AGIBOT X2

AGIBOT X2

AGIBOT · Humanoid

Education and programming · Research and development

Price not disclosed

ClaimedPaper announcement
ASIMO

ASIMO

Honda · Humanoid

Research and development

Price not disclosed

ClaimedPaper announcement
Booster K1

Booster K1

Booster Robotics · Humanoid

Research and development

Price not disclosed

ClaimedPaper announcement
Hydraulic Atlas

Hydraulic Atlas

Boston Dynamics · Humanoid

Research and development

Price not disclosed

Light sheet
Cite this sheet

Plain citation

“Reachy 2”, Vuntum, updated 29 September 2026, https://vuntum.com/en/robots/pollen-reachy-2

APA format

Vuntum. (2026, September 29). Reachy 2. https://vuntum.com/en/robots/pollen-reachy-2

Embed this badge

Vuntum sheet: Reachy 2

To show on your site how many sourced values this sheet holds, linking back to it.

HTML code

<a href="https://vuntum.com/en/robots/pollen-reachy-2"><img src="https://vuntum.com/badge/pollen-reachy-2.svg?lang=en" alt="Vuntum sheet: Reachy 2" height="20"></a>

Shields.io address (README, other styles)

https://img.shields.io/endpoint?url=https%3A%2F%2Fvuntum.com%2Fapi%2Fv1%2Frobots%2Fpollen-reachy-2%2Fbadge%3Flang%3Den